MICRODUCK HARDWARE
Know YourHardware
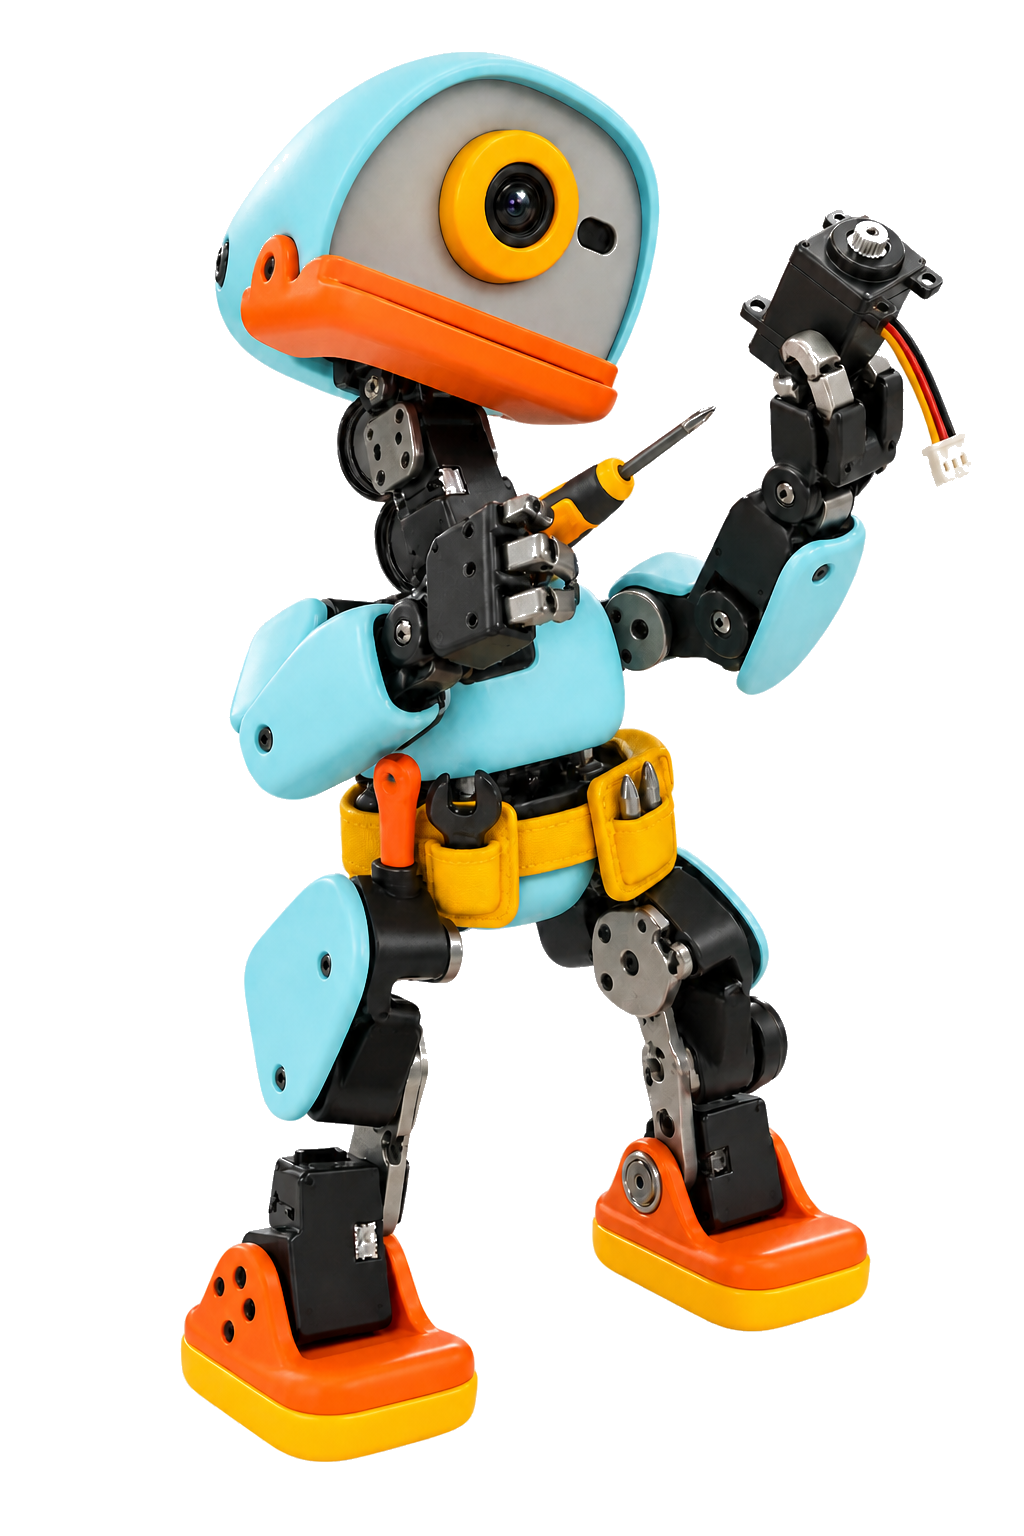
Official robots, open reconstruction projects, accessories, replacement parts, and community modifications.- ROBOTS
- 15
- ACCESSORIES
- 1
- PARTS + MODS
- 2
 01ACCESSORIES
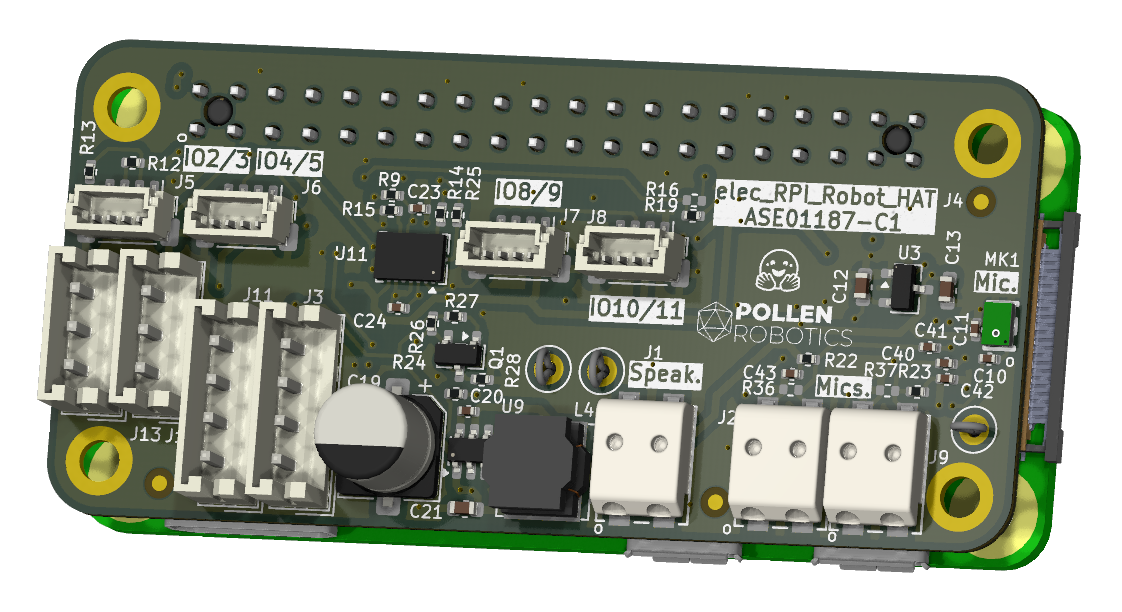
RPI Robot HAT
An official Raspberry Pi Zero-sized robotics HAT with IMU, TTL and RS-485 servo buses, audio I/O, and Qwiic expansion.
OptiDuck
Physical Microduck-derived biped using a Radxa Zero 3W and lower-cost Feetech bus servos, with MuJoCo/mjlab PPO training, ONNX deployment, board services and an Android maintenance app. hardware-ready open-source chinese onnx
BruzMicroduck CAD
Compact CAD repository for a Microduck replica adapted around off-the-shelf sensors, boards and components, separating official reference geometry from editable replica-specific STEP designs. hardware-ready open-source community
MicroDuck BoBoRedesign
Work-in-progress redesign of the Microduck shell and structure for FDM/SLA printing, organized for printable STL/STEP parts, PCB, firmware and reinforcement-learning assets. hardware-ready open-source community
 05ROBOTS
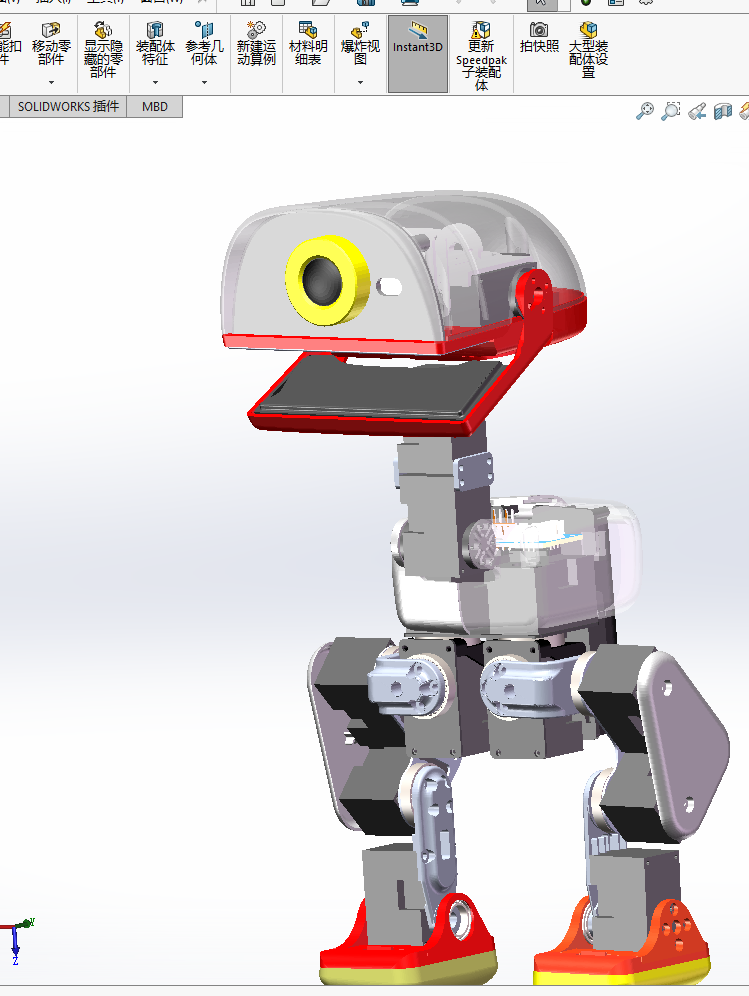
microduck-replica-cad
The companion drawing set for that reconstruction: 56 editable SolidWorks parts and assemblies rather than meshes, plus a 21-page assembly manual, modelled from scratch by a named author. In Chinese.
 06ROBOTS
Microduck DIY build docs
Documentation companion to that build: bill of materials, printing, wiring, phased assembly, servo and IMU commissioning and first walk, with the software left upstream. Apache-2.0, in Chinese.
 07ROBOTS
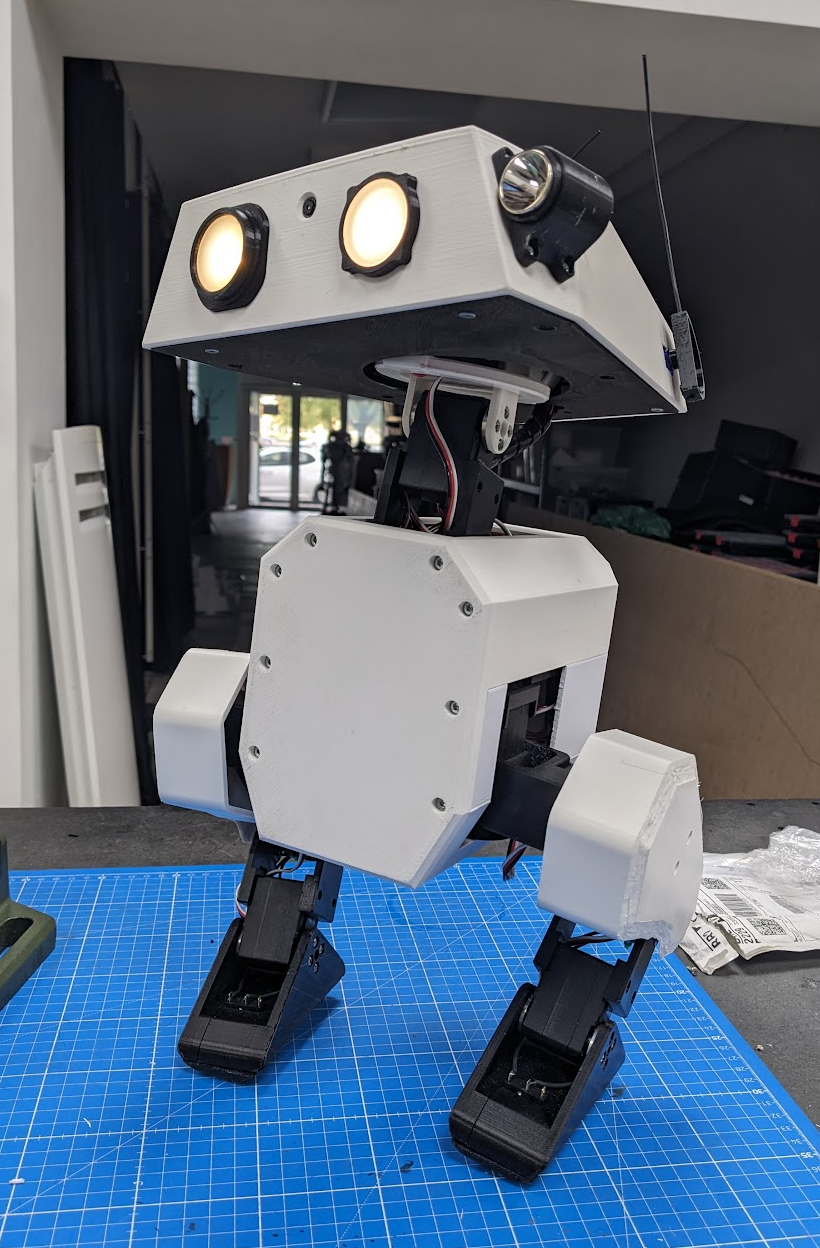
Microduck Replica Kit
Evidence-traceable reconstruction package that separates upstream facts from reproducible derivations and open questions, with an assembly exporter for the 47 public meshes and a staged bill of materials. Walking hardware is not finished. In Chinese.
 08ROBOTS
Open Duck Mini
The open-hardware predecessor: BOM, CAD, and the original mjlab training work.
 09ROBOTS
Fanduck
A finished replica, with photographs and video of a working duck built from parts sourcing through printing to assembly, and the maker pack mirrored alongside: bill of materials, print files, board files and a 3D pose workbench. Its licence file pins the upstream commit everything derives from and flags the official mechanical model as non-commercial. In Chinese.
 10ROBOTS
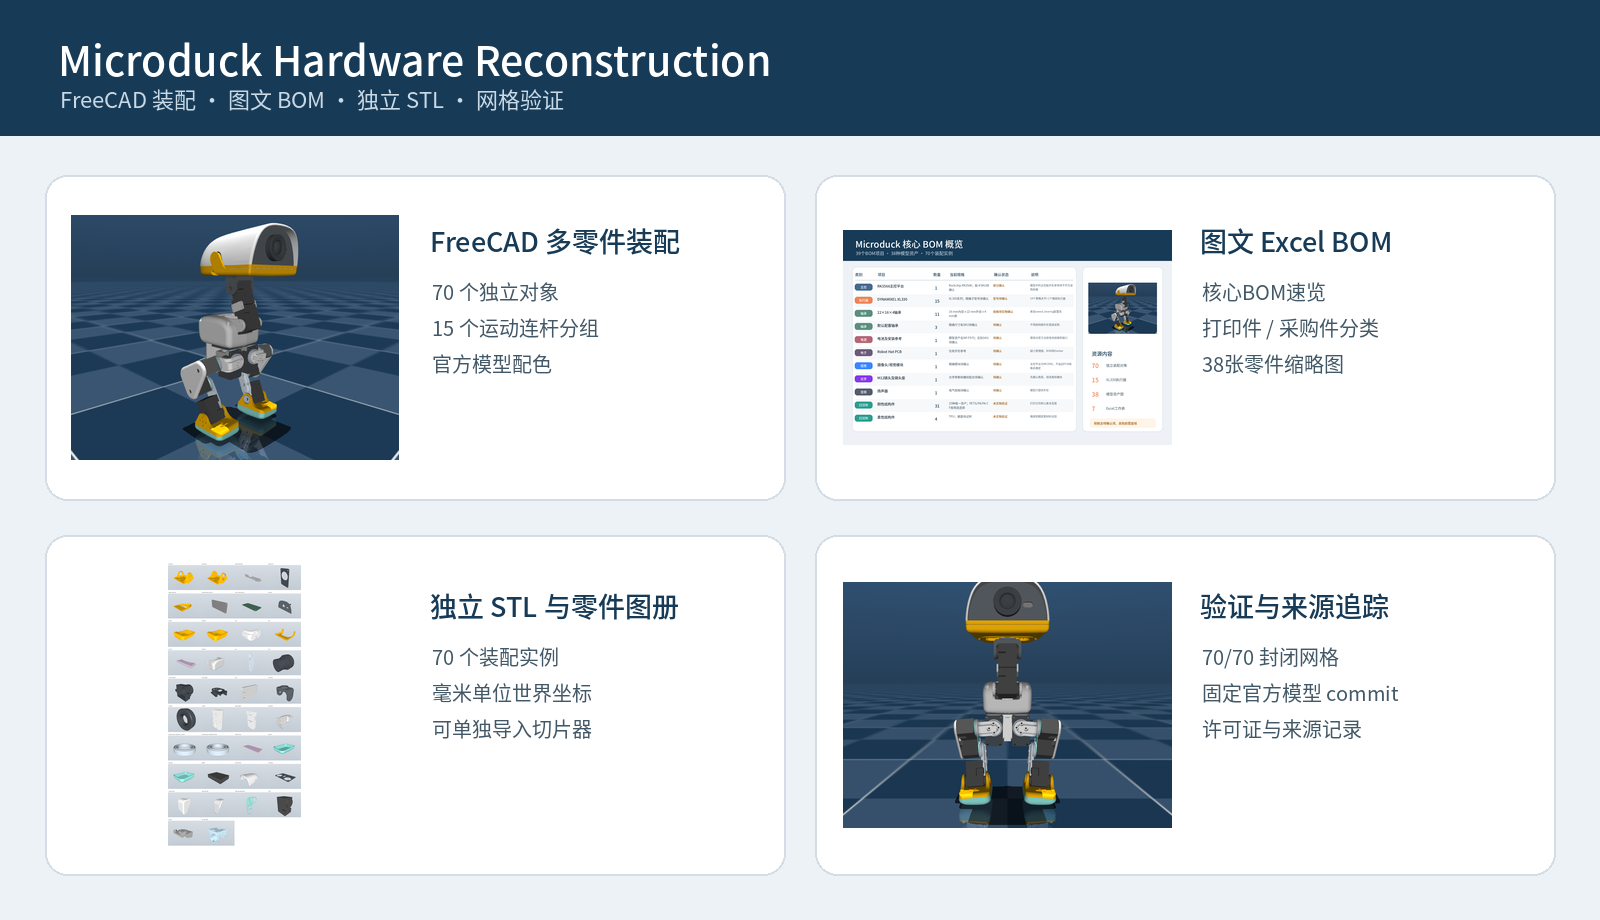
microduck-hardware-replica
FreeCAD multi-part assemblies, printable meshes and a planning-stage bill of materials derived from the public MJCF and STL models. In Chinese, and explicit that it is unaffiliated and unverified.
 11ROBOTS
Microduck build tutorial
End-to-end build of a working small biped on a Raspberry Pi Zero 2 W: wiring, a flashable image, Wi-Fi and SSH setup, printable files, the deployment code that drives the Dynamixel bus from an ONNX gait, and the mjlab environment that trains it. Walking hardware on video. In Chinese.
 12ROBOTS
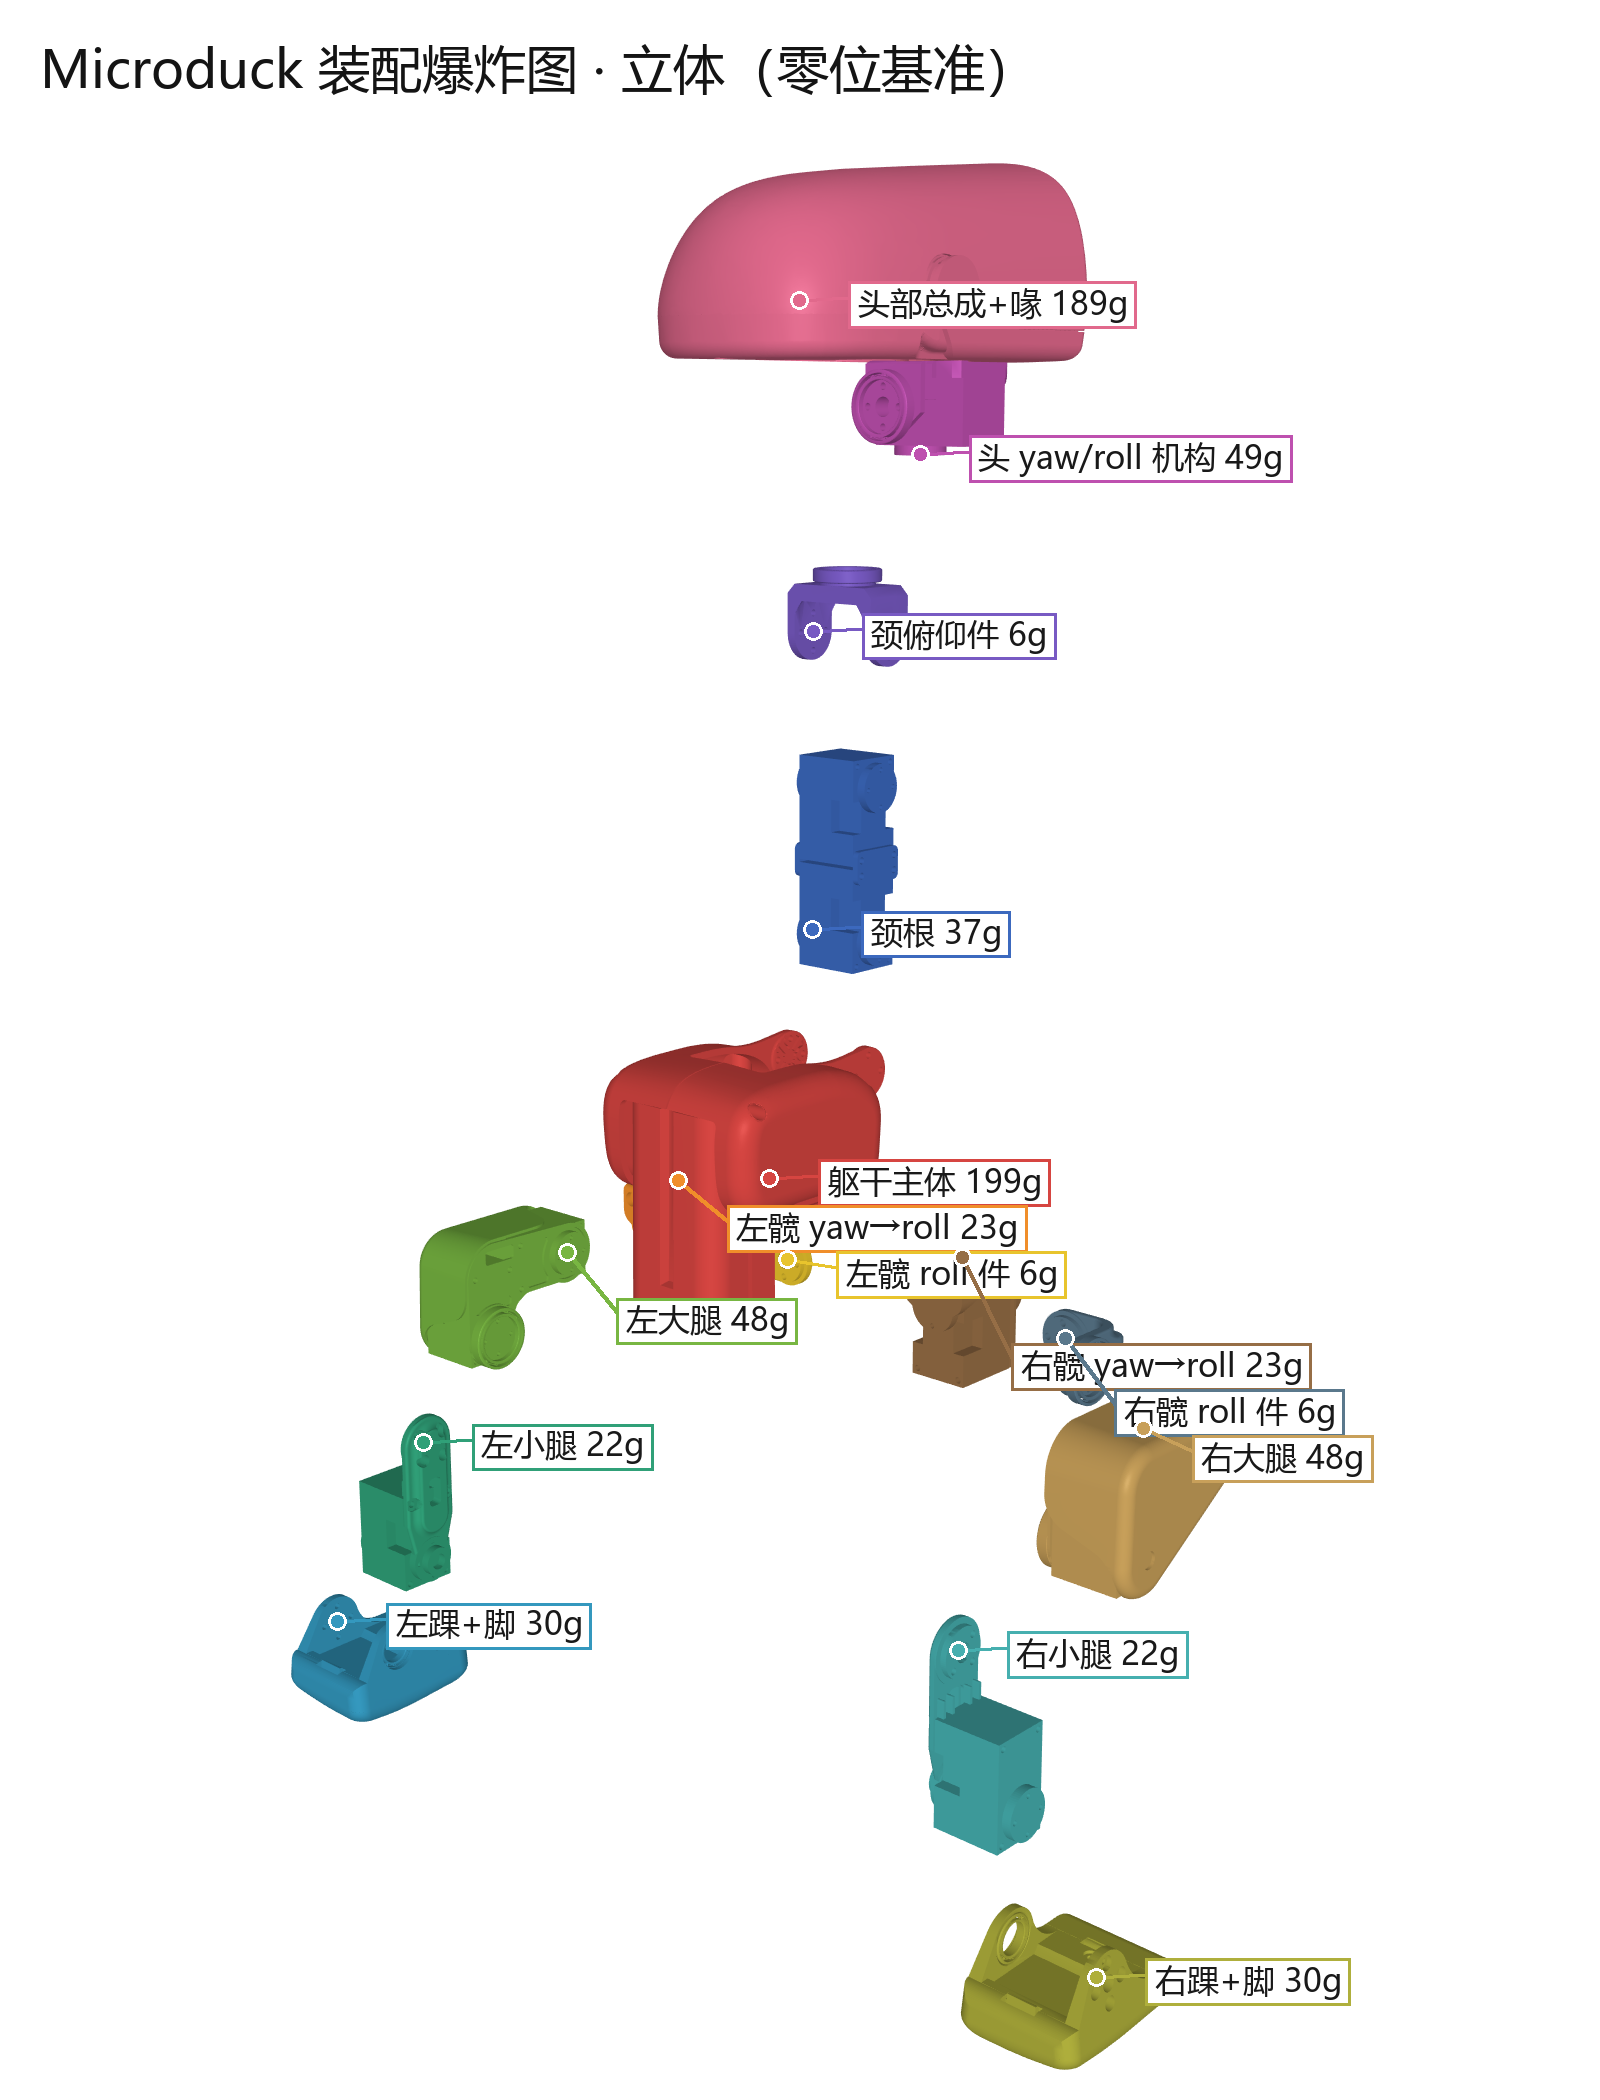
microduck-replica
Reconstruction study deriving assembly and exploded drawings, CAD-importable assemblies, a fastener list and an electronics teardown (Radxa Zero 3W, TTL servo bus, the two custom boards) from the public MJCF, STL meshes and runtime source, in English and Chinese and not verified against physical hardware.
 13ROBOTS
ChinaMicroDuck
Replication reference library: four costed manufacturing routes compared, an audit of which official assets may be reused under which license, environment verification reports and Chinese translations of the official docs.
 14ROBOTS
OpenMicroDuck
Independent reverse-engineering and documentation project mapping what the robot contains and how its stack works, in English and Chinese, explicit that the hardware is not open source.
 15ROBOTS
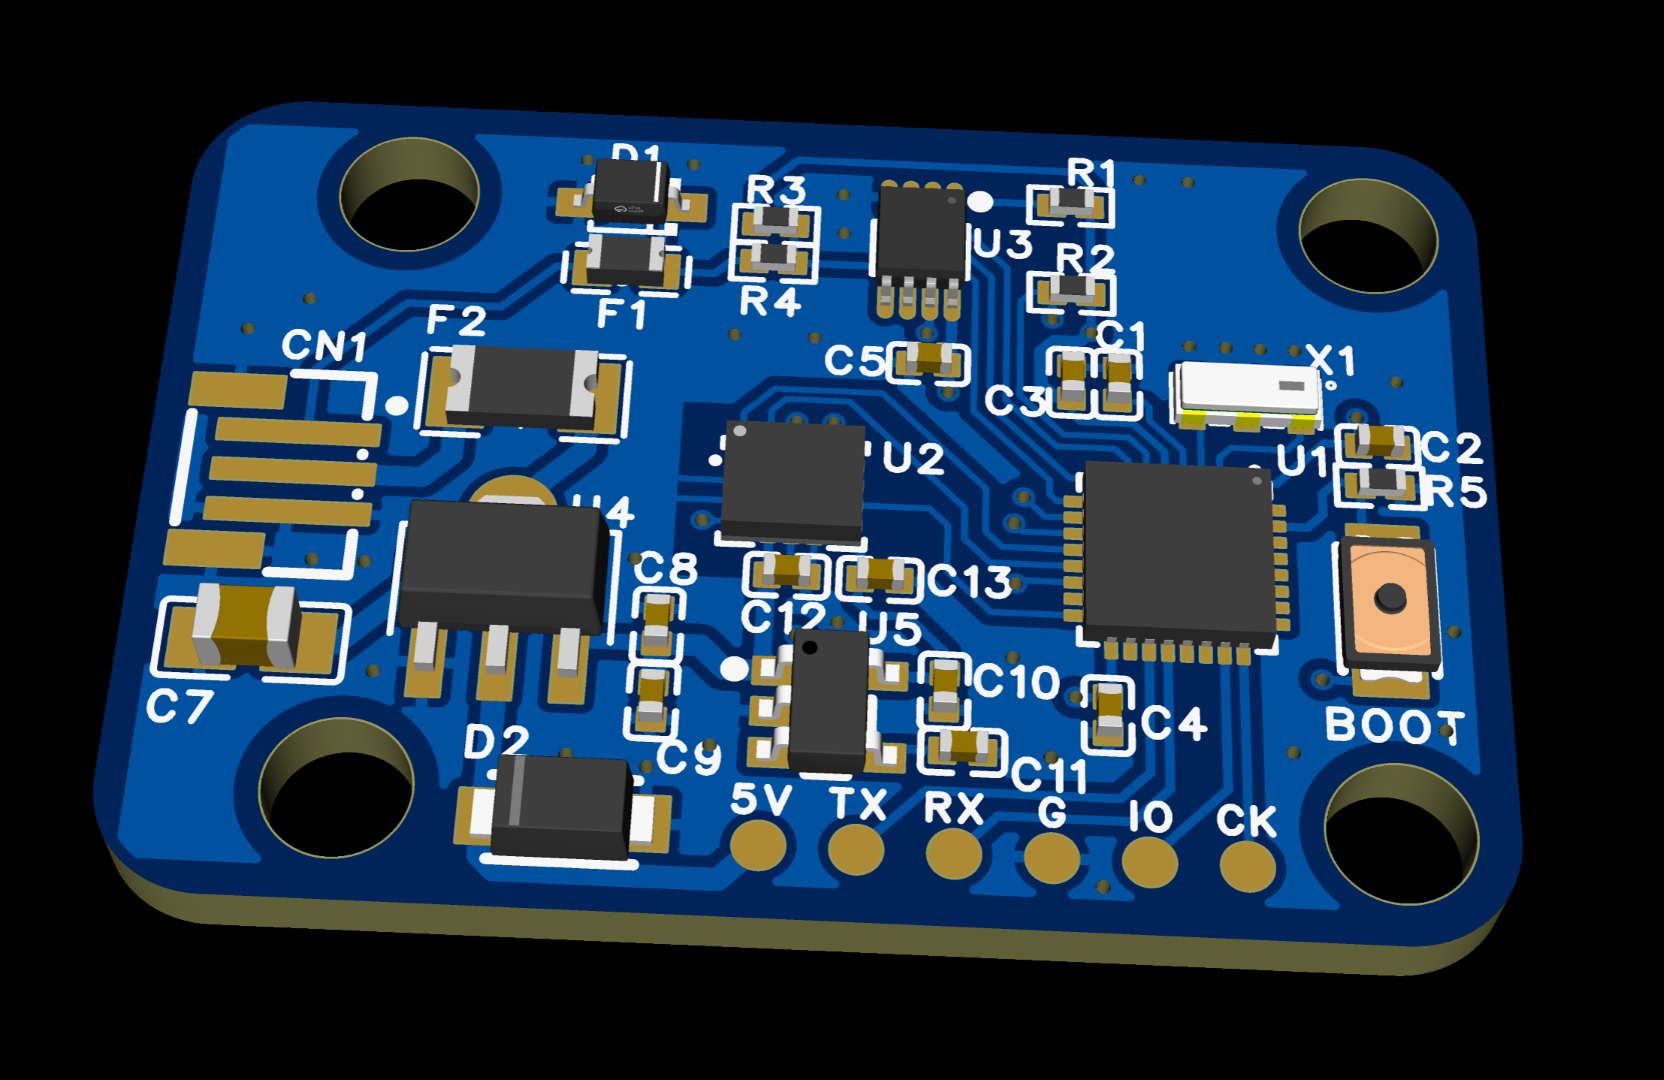
microduck_imu_to_ttl
Open-hardware imu_to_dxl board putting an LSM6DSV16X on the half-duplex Dynamixel bus, with its own regulation and transceiver buffering, schematic and block diagram published and the project also on OSHWHub. Fills one of the parts the replica projects list as still to be designed. Apache-2.0, in Chinese.
 16ROBOTS
microduck-diy
Month-long build log for a hand-made duck from the public simulation meshes and printable parts, with staged files and a parts list. In Chinese.
 17ROBOTS
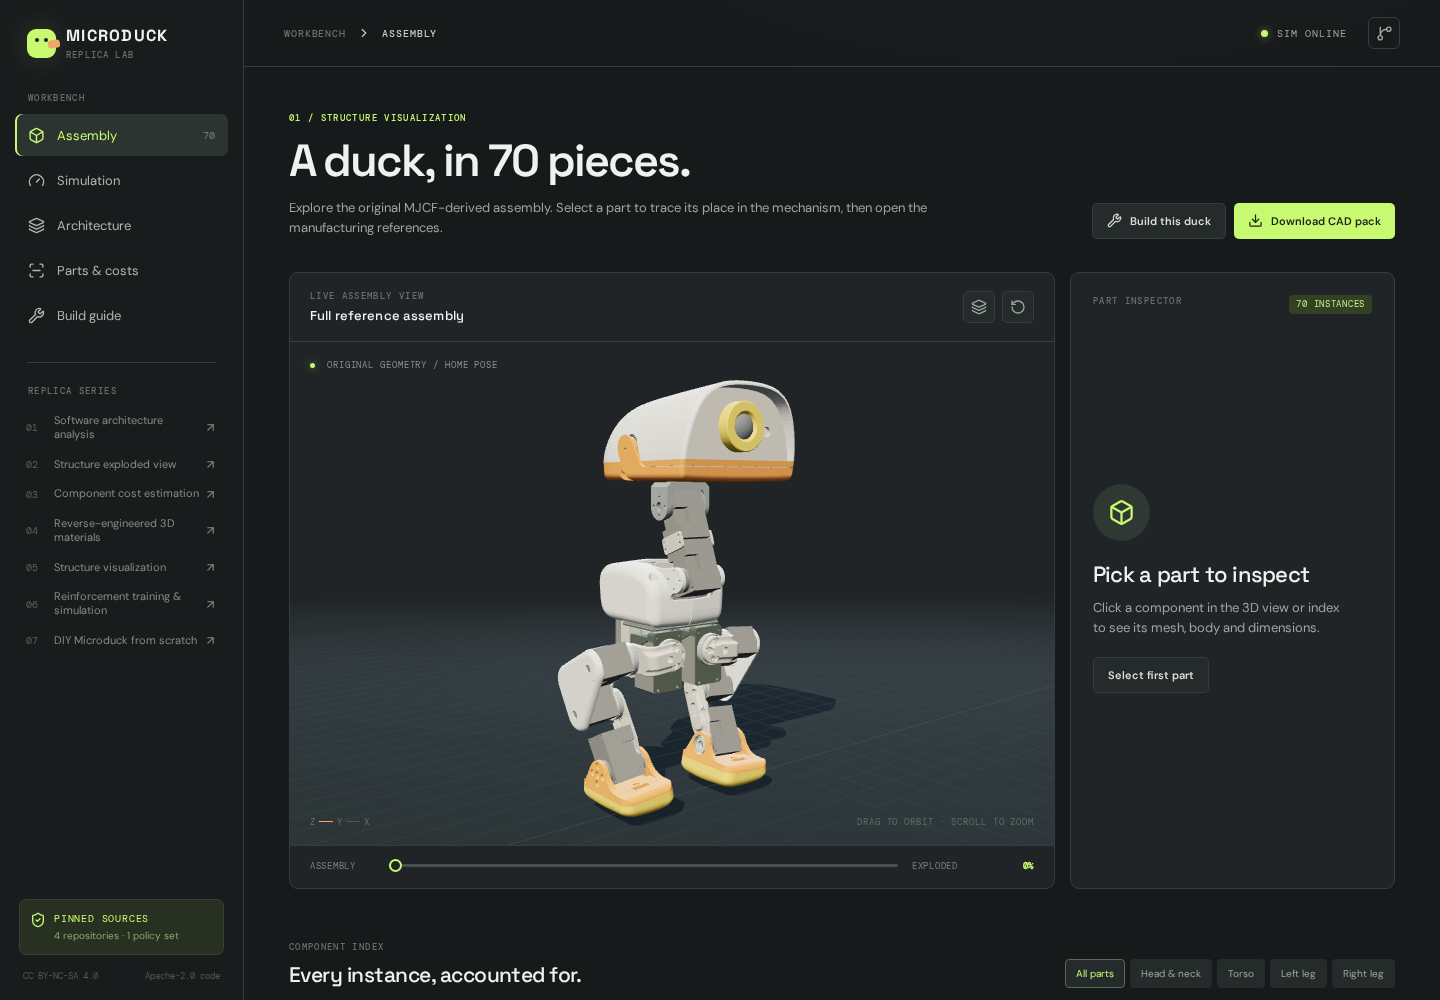
Microduck Replica Lab
Assembly explorer, a rehearsal of the published walking policy, reference CAD, build instructions and US and China sourcing guides. Code is Apache-2.0 while reference geometry stays under CC BY-NC-SA with a license map, and the project says it is not a tested kit.
 18ROBOTS
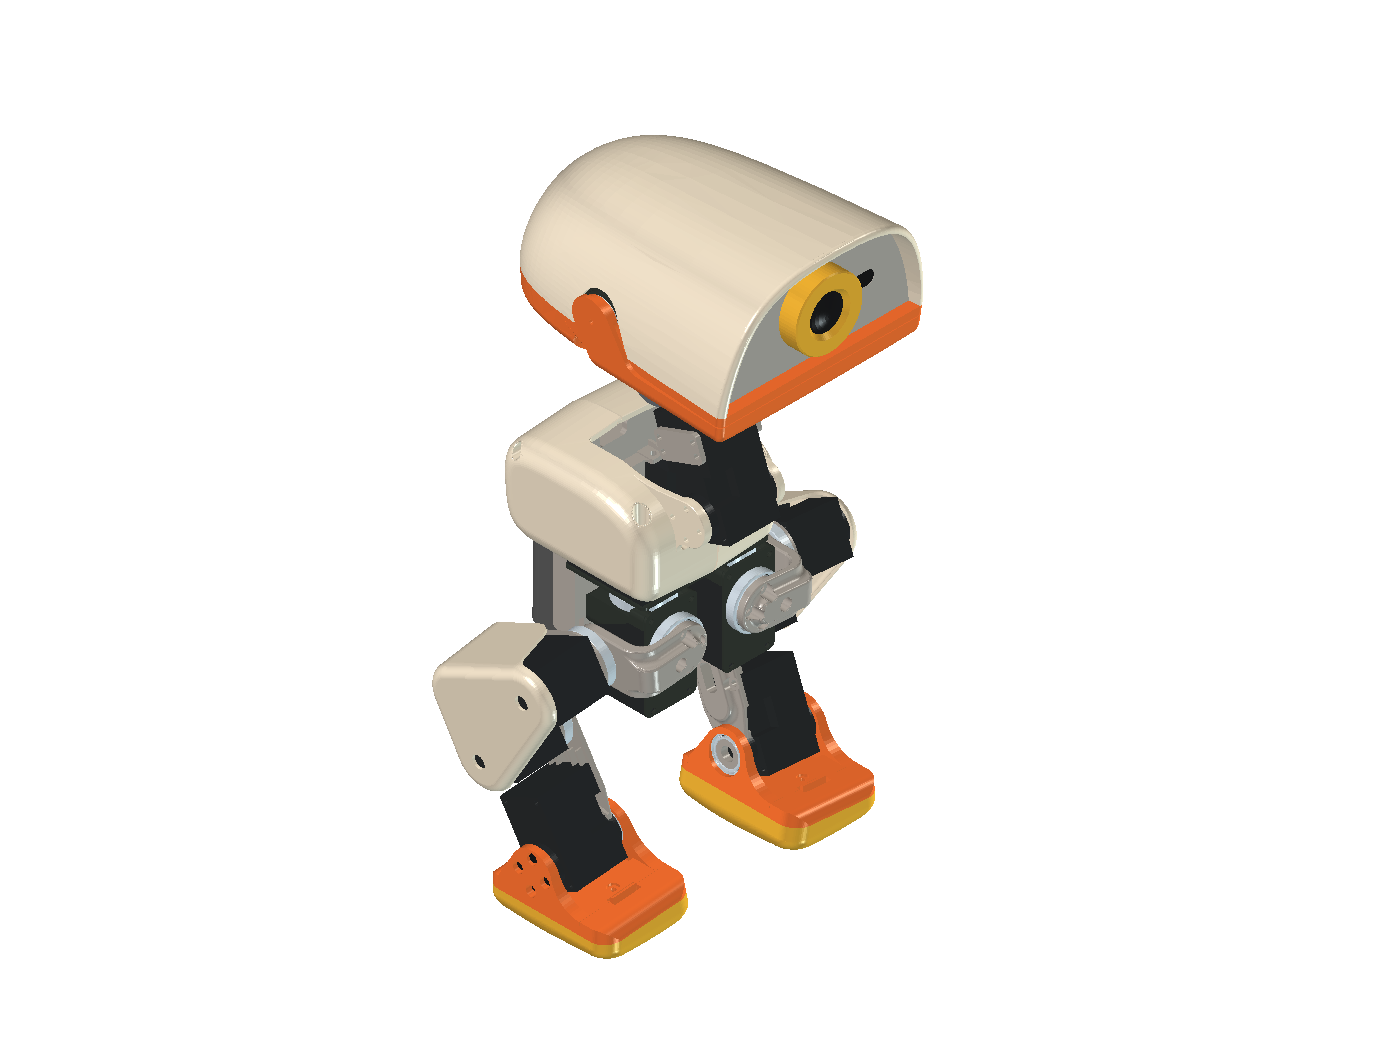
OpenMicroDuck (FreeCAD)
FreeCAD model and engineering drawings alongside a keyboard-driven MuJoCo simulation with walking, sitting and standing, fall recovery and jaw control, plus ramp and low-grip test scenes. Apache-2.0, in Chinese and still iterating; unrelated to the reverse-engineering project of the same name above.