RPI Robot HAT
An official Raspberry Pi Zero-sized robotics HAT with IMU, TTL and RS-485 servo buses, audio I/O, and Qwiic expansion.
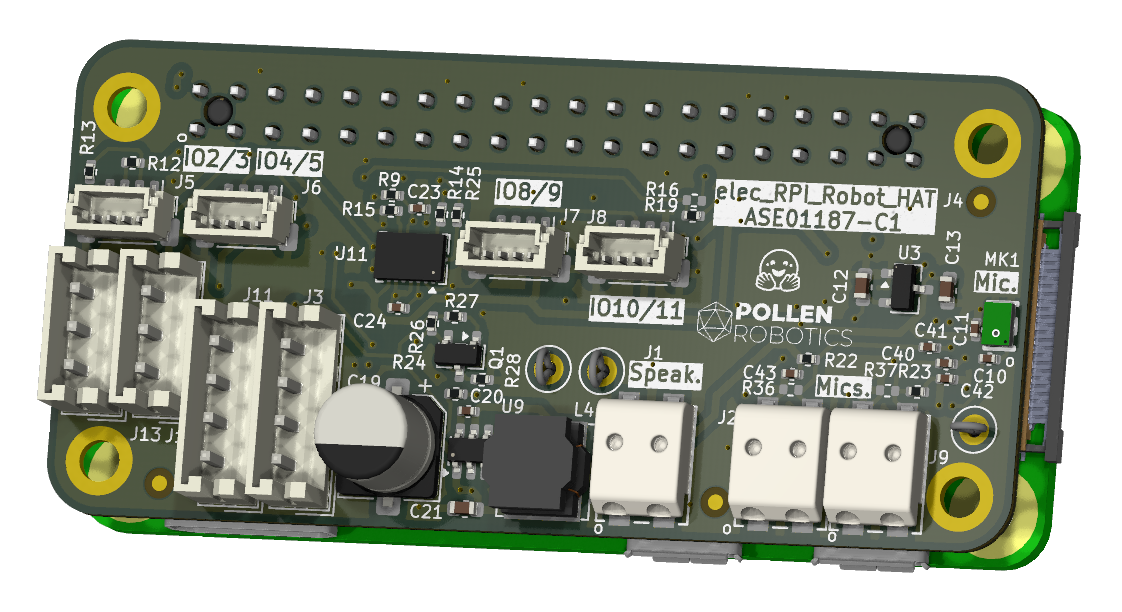
RPI Robot HAT
The RPI Robot HAT is an open-source robotics carrier designed around the Raspberry Pi Zero footprint. It combines robot power, sensing, actuator communication, and audio on one KiCad 9 board.
Interfaces
- I2C IMU
- TTL and RS-485 buses for Dynamixel or adapted Feetech servos
- Integrated MEMS microphone and audio output with loudspeaker/external microphone connectors
- 1 mm, 3.3 V Qwiic expansion connectors
- 5–28 V input through the motor connector
Published hardware assets
The repository includes editable KiCad project files, production BOM and placement CSV files, schematic and PCB PDFs, PCB fabrication archives, and a STEP export. Consult the schematics and HAT specification before selecting Qwiic interfaces or adapting servo cabling.
Verification boundary
This record describes the published board design and files. It does not independently certify a fabricated board revision or electrical safety for a particular build.
Specifications
- Form factor
- Fits Raspberry Pi Zero
- Input voltage
- 5–28 V
- Servo communication
- TTL and RS-485
- Sensors
- I2C IMU
- Audio
- MEMS microphone, audio input/output, loudspeaker connector
- Expansion
- 1 mm / 3.3 V Qwiic connectors
- Design tool
- KiCad 9
Compatible Policies
No compatibility claims have been published.