 PROJECT PREVIEW
microduck-walking yaw ablation
Single-variable reward ablation that cuts yaw-rate variance against the released alpha_walking baseline, with the evaluation harness that makes the comparison reproducible. Sim-only.
https://github.com/alertform/microduck-walking61 OBSERVATIONS 14 ACTIONS 50 HZ COMPATIBILITY NOT INDEPENDENTLY VERIFIED
AWESOME MICRODUCK INDEX
microduck-walking yaw ablation
Single-variable reward ablation that cuts yaw-rate variance against the released alpha_walking baseline, with the evaluation harness that makes the comparison reproducible. Sim-only.
Project Overview
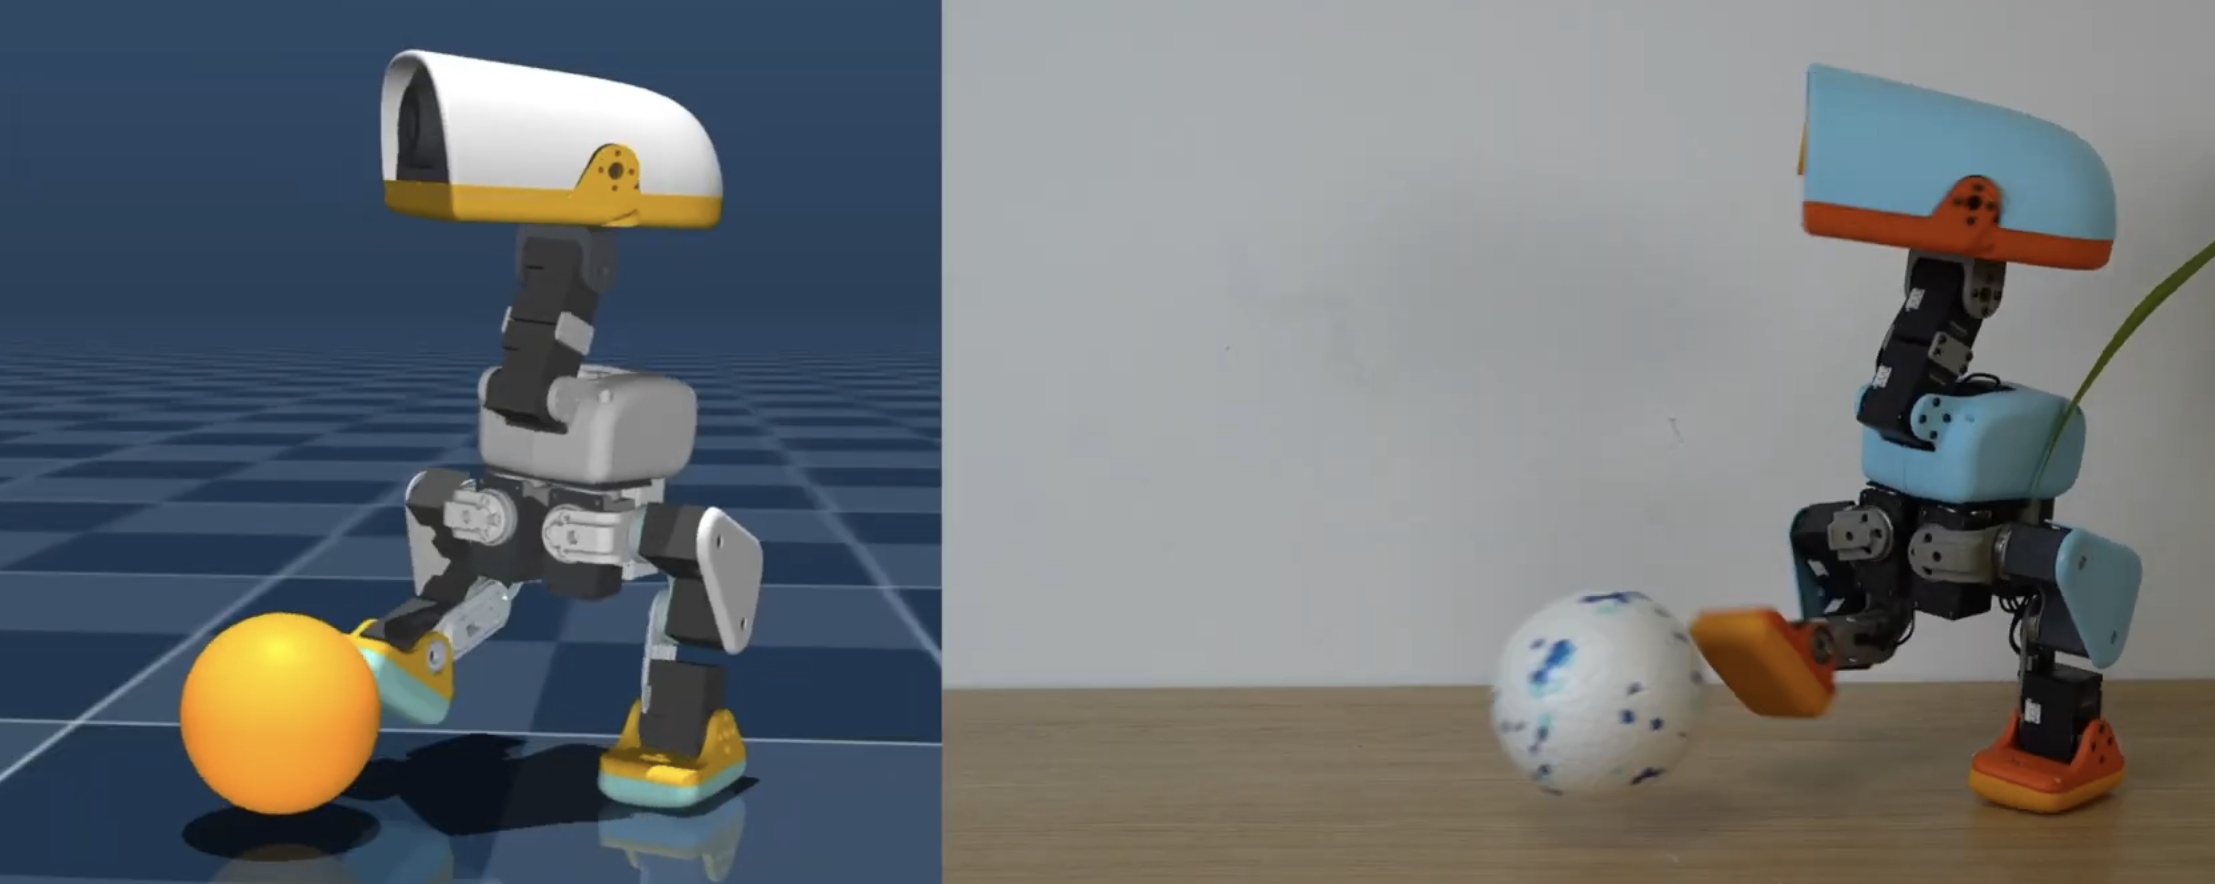
RL training environments for Microduck — a ~800 g, ~25 cm tall bipedal robot — built on mjlab (MuJoCo Warp) with PPO. Policies are trained here at 50 Hz, exported to ONNX, and deployed on the real robot by the runtime in pollen-robotics/microduck.
Keep it short (~30 s) and real-robot-first: this is the "why should I care" shot. --
https://github.com/user-attachments/assets/50c3d537-8db2-4005-9d9c-3472faeec4d0
Task
| Field | Value |
|---|---|
| Source | GITHUB SOURCE |
| Runtime contract | 61 observations / 14 actions / 50 Hz |
| Verification | Pending independent Duckio review |
| Artifact | Not indexed |
Source Coverage
The upstream README includes: Quickstart, Tasks, Backlash variants, Actuator model, Robot models, Project structure, Tests, Related projects.
Intended Use
Use this entry to assess the project and locate its canonical implementation. Read the complete README, inspect the manifest and artifacts, and reproduce the source's evaluation before assigning simulation or hardware verification.